Tutorial 3: Authentic SPIKE Python Programming & Autonomous Navigation
While visual Word Blocks are fantastic for getting started, text-based Python provides the ultimate speed, algorithmic precision, and mathematical control for high-scoring FIRST® LEGO® League competition teams.
In this tutorial, you will write authentic Python scripts using the official spike library syntax, implement closed-loop Gyro IMU pivot turns, design a smooth Proportional (P-Controller) Line Follower, build an error-eliminating Dual-Sensor Line Squaring routine, and debug issues using the simulator's Live Event Log Stream.
🎯 Learning Objectives
By the end of this tutorial, you will be able to:
- Import and instantiate
PrimeHub,MotorPair,ColorSensor, and control timers from thespikelibrary. - Replace inconsistent dead-reckoning wheel turns with closed-loop Gyro 90° Precision Tank Turns.
- Understand the mathematics of a Proportional (P) Controller to track the boundary of field lines without oscillating.
- Program a Dual-Sensor Line Squaring algorithm that realigns the robot's heading to zero-drift precision.
- Inspect the Live Command & Event Logs stream to diagnose motor latency, sensor polling rates, and physics collisions.
- Solve Hands-On Challenge 3 by programming a multi-stage autonomous navigation routine.
🐍 Step 1: Writing Python for the Virtual SPIKE Prime Hub
In fll-sim, the Python environment runs directly in your browser using an asynchronous Python-to-TypeScript runtime that faithfully implements the official LEGO SPIKE Prime Python API.
To switch to Python mode: 1. Open the Code Editor (either in the side drawer or popout modal). 2. Click the 💻 Python toggle button in the header bar. 3. You now have a full-featured code editor with syntax highlighting and auto-indentation.
The Essential SPIKE Library Imports
Every competition script typically begins with these core imports:
from spike import PrimeHub, MotorPair, ColorSensor, Motor
from spike.control import wait_for_seconds

# Initialize the Hub (provides access to the 6-axis Gyro IMU)
hub = PrimeHub()

# Initialize differential drive motors on Ports A and B
motors = MotorPair('A', 'B')

# Initialize optical color sensors on Ports C (Left) and D (Right)
color_left = ColorSensor('C')
color_right = ColorSensor('D')
Crucial Concept: wait_for_seconds() in Simulation
In physical MicroPython on the SPIKE Hub, a time.sleep() halts the processor core. In a browser simulation, however, calling blocking sleeps freezes the WebGL render loop!
Always use from spike.control import wait_for_seconds. The simulator's wait_for_seconds() yields execution cooperatively back to the browser, allowing the Rapier 3D physics engine and Three.js canvas to step forward at a rock-solid 60 FPS while your loop runs.
🧭 Step 2: Gyro 90-Degree Precision Tank Turn
Why Do "Turn for Degrees" Moves Fail in FLL?
Many rookie teams program turns by running one wheel forward for \(180^\circ\) and the other backward for \(180^\circ\). While this works on clean paper, it constantly drifts on competition mats due to: * Dust and static friction differences on vinyl surfaces. * Varying battery voltage (a low battery turns slower than a fresh battery). * Center-of-mass shifts from heavy attachment arms.
The professional solution is closed-loop feedback using the Hub's internal 6-axis Gyroscope!
flowchart TD
    A["Reset Gyro Yaw to 0.0°"] --> B["Start Counter-Rotating Motors\nLeft: +35%, Right: -35%"]
    B --> C{"Is Gyro Yaw >= 90.0°?"}
    C -- No --> D["wait_for_seconds(0.01)\nPoll Sensor"]
    D --> C
    C -- Yes --> E["Brake Motors\nmotors.stop()"]
    E --> F["Turn Complete at 90°!"]
Gyro Turn Implementation:
from spike import PrimeHub, MotorPair
from spike.control import wait_for_seconds

hub = PrimeHub()
motors = MotorPair('A', 'B')

# 1. Reset Gyro Yaw heading to zero
hub.motion_sensor.reset_yaw_angle()
wait_for_seconds(0.2)  # Brief pause for IMU baseline settling

print("Starting Gyro 90° Pivot Turn...")

# 2. Start a tank pivot (Left wheel forward, Right wheel backward)
motors.start_tank(35, -35)

# 3. Closed-loop monitoring: keep turning until 90 degrees reached
while hub.motion_sensor.get_yaw_angle() < 90:
    wait_for_seconds(0.01)

# 4. Instant active braking
motors.stop()

final_yaw = hub.motion_sensor.get_yaw_angle()
print(f"Turn successfully locked in at Yaw: {final_yaw:.1f}°")
Key Parameters:
start_tank(35, -35): Turning at \(35\%\) speed ensures the robot doesn't overshoot \(90^\circ\) due to rotational inertia.get_yaw_angle(): Returns the instantaneous angular orientation relative to the last zero point.wait_for_seconds(0.01): High-frequency 100 Hz sensor polling loop.
〰️ Step 3: Proportional Line Follower (P-Controller)
On an FLL field, black guide lines link your launch sector directly to key mission models. Simple "two-state" (bang-bang) line followers oscillate violently back and forth like a snake.
A Proportional (P) Controller calculates the mathematical error between where the robot is and where it wants to be, smoothly adjusting steering proportionally to that error.
flowchart LR
    Target["Target Light\n50% (Line Edge)"] --> Diff["Calculate Error:\nError = Target - Light"]
    Sensor["ColorSensor('C')\nLight Reading"] --> Diff
    Diff --> Gain["Multiply Gain:\nSteering = Error * Kp"]
    Gain --> Drive["motors.start(steering, speed)"]
The Mathematics:
- Target: We follow the edge where white vinyl (\(90\%\) light) meets black line (\(20\%\) light). The target is the midpoint: $\(\text{Target} = 50\%\)$
- Error: The difference between our target and what Color Sensor C currently sees: $\(\text{Error} = \text{Target} - \text{Reflected Light}\)$
- Steering Correction: $\(\text{Steering} = \text{Error} \times K_p\)$ where \(K_p\) is the Proportional Gain (typically \(0.7 \text{ to } 1.0\)).
Proportional Line Follower Implementation:
from spike import MotorPair, ColorSensor
from spike.control import wait_for_seconds

motors = MotorPair('A', 'B')
color_c = ColorSensor('C')  # Left downward optical sensor

TARGET_LIGHT = 50   # 50% reflected light = edge of black line
KP = 0.85           # Proportional tuning constant
CRUISE_SPEED = 35   # Stable driving speed

print("Engaging Proportional Line Tracking...")

# Run line follower for 250 control cycles (approx. 5 seconds)
for cycle in range(250):
    current_light = color_c.get_reflected_light()

    # Calculate error and steering adjustment
    error = TARGET_LIGHT - current_light
    steering = error * KP

    # Apply steering correction with forward velocity
    motors.start(steering=int(steering), speed=CRUISE_SPEED)
    wait_for_seconds(0.02)  # 50 Hz control loop

motors.stop()
print("Line tracking complete!")
Tuning Proportional Gain (\(K_p\))
- If \(K_p\) is too low (\(< 0.4\)): The robot responds too sluggishly and drifts off sharp line curves.
- If \(K_p\) is too high (\(> 1.5\)): The robot jerks and oscillates violently.
- For the Advanced Driving Base in
fll-sim, a \(K_p\) between \(0.75\) and \(0.90\) provides glass-smooth tracking!
📐 Step 4: Dual-Sensor Line Squaring Algorithm
In high-level FLL competition, teams cannot rely on odometry alone across a long 2.5-minute run. Small tire slips accumulate into large positional errors.
The Dual-Sensor Line Squaring routine is the gold standard for resetting positional and angular error: as the robot approaches a black perpendicular line, each wheel moves independently until both downward sensors detect black. The robot is then mathematically guaranteed to be square (\(90.0^\circ\)) to the line!
sequenceDiagram
    participant Robot as Chassis (Motors A & B)
    participant SensC as Sensor C (Left)
    participant SensD as Sensor D (Right)
    participant Mat as Black Field Line

    Note over Robot,Mat: Phase 1: Drive forward toward line
    Robot->>Mat: Driving at 30% speed
    SensC-->>Robot: Sees White (85%)
    SensD-->>Robot: Sees White (85%)
    SensC->>Mat: Hits Black Line (20%)!
    Robot->>Robot: Stop forward movement!

    Note over Robot,Mat: Phase 2: Independent wheel creeping
    loop Until Both on Black Line
        alt Left Sensor still on White?
            Robot->>Robot: Creep Left Wheel (A) at 15%
        else Left Sensor on Black?
            Robot->>Robot: Brake Left Wheel (A) at 0%
        end
        alt Right Sensor still on White?
            Robot->>Robot: Creep Right Wheel (B) at 15%
        else Right Sensor on Black?
            Robot->>Robot: Brake Right Wheel (B) at 0%
        end
    end
    Note over Robot,Mat: Robot is now 100% Squared!
Line Squaring Implementation:
from spike import MotorPair, ColorSensor
from spike.control import wait_for_seconds

motors = MotorPair('A', 'B')
sensor_c = ColorSensor('C')  # Left sensor
sensor_d = ColorSensor('D')  # Right sensor

BLACK_THRESHOLD = 30  # Light < 30% indicates black tape

print("Phase 1: Driving toward black line...")
motors.start(steering=0, speed=30)

# Drive forward until EITHER sensor detects the line
while sensor_c.get_reflected_light() > BLACK_THRESHOLD and sensor_d.get_reflected_light() > BLACK_THRESHOLD:
    wait_for_seconds(0.01)

motors.stop()
print("Line detected! Phase 2: Squaring heading...")

# Align both wheels until BOTH sensors rest precisely on black
for step in range(120):
    left_light = sensor_c.get_reflected_light()
    right_light = sensor_d.get_reflected_light()

    # Move each wheel only if its sensor hasn't reached black yet
    left_speed = 15 if left_light > BLACK_THRESHOLD else 0
    right_speed = 15 if right_light > BLACK_THRESHOLD else 0

    # If both wheels have reached the black line, we are perfectly square!
    if left_speed == 0 and right_speed == 0:
        print("Both sensors locked on black line!")
        break

    motors.start_tank(left_speed, right_speed)
    wait_for_seconds(0.02)

motors.stop()
print("Robot perfectly squared to field line!")
🔍 Step 5: Debugging with the Command & Event Logs Stream
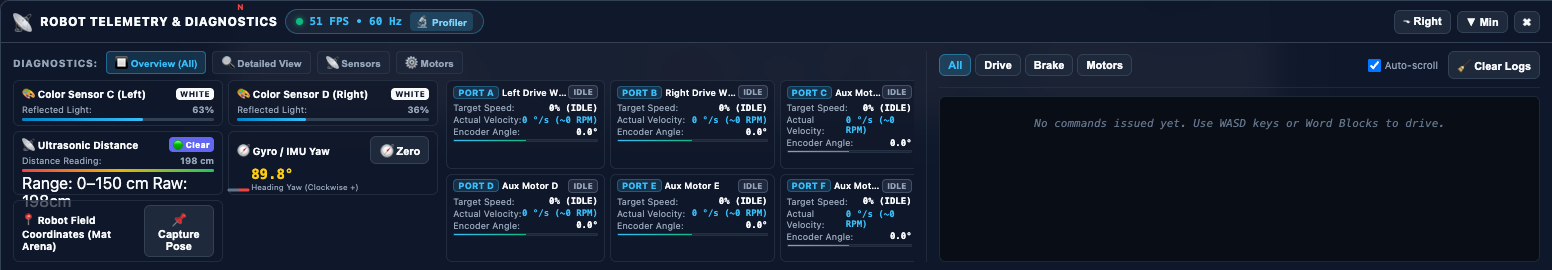
When an autonomous routine doesn't behave as expected, don't guess—check the Live Telemetry & Event Stream!
Click 📡 Telemetry in the top bar to inspect the log stream in the right column:
What the Event Stream Displays:
[CMD: MOTOR_START_TANK]: Confirms the exact left and right speeds transmitted to the Rapier physics joints.[EVENT: GYRO_POLL]: Real-time yaw degree readings with timestamps.[EVENT: SENSOR_COLOR]: Reflected light percentage snapshots when color thresholds trigger.[BRAKE: HOLD]: Verifies that active motor braking engaged immediately without coasting.
You can filter entries using the filter chips: * All: Full system log. * Drive: Differential steering and forward moves. * Brake: Stopping events and motor hold commands. * Motors: Encoder readouts and auxiliary attachment movement.
🏆 Hands-On Challenge 3: Turn, Track & Square Sequence
Combine all three autonomous techniques into a single, tournament-grade navigation routine!
Challenge Prompt:
Mission Scenario: 1. Start inside the Red Launch Arc facing East (\(90^\circ\)). 2. Execute a precision Gyro Pivot Turn \(45^\circ\) to the left to align with the diagonal field line (Target Yaw = \(45.0^\circ\)). 3. Drive forward using the Proportional Line Follower for \(3.0\) seconds along the line edge. 4. Disengage line following and perform a Dual-Sensor Line Squaring maneuver against the cross-line. 5. Print a final diagnostic report confirming that both sensors read black and reporting the calibrated Gyro heading.
Challenge 3 Solution
from spike import PrimeHub, MotorPair, ColorSensor
from spike.control import wait_for_seconds

# 1. Hardware Initialization
hub = PrimeHub()
motors = MotorPair('A', 'B')
color_left = ColorSensor('C')
color_right = ColorSensor('D')

# Calibrate Gyro
hub.motion_sensor.reset_yaw_angle()
wait_for_seconds(0.2)
print("=== MISSION RUN: TURN, TRACK & SQUARE ===")

# STEP 1: Precision Gyro Turn to 45 degrees
print("Step 1: Pivot turning to 45 degrees...")
motors.start_tank(-30, 30)  # Counter-clockwise pivot
while hub.motion_sensor.get_yaw_angle() > -45:
    wait_for_seconds(0.01)
motors.stop()
print(f"Turn complete. Current Yaw: {hub.motion_sensor.get_yaw_angle():.1f}°")

# STEP 2: Proportional Line Follower on Color Sensor C
print("Step 2: Tracking line for 3 seconds...")
TARGET_LIGHT = 50
KP = 0.8
CRUISE_SPEED = 35

for step in range(150):  # 150 cycles * 0.02s = 3.0 seconds
    light = color_left.get_reflected_light()
    error = TARGET_LIGHT - light
    steering = int(error * KP)
    motors.start(steering, CRUISE_SPEED)
    wait_for_seconds(0.02)

motors.stop()
print("Step 2 complete.")

# STEP 3: Dual-Sensor Line Squaring
print("Step 3: Squaring against cross-line...")
motors.start(0, 25)
while color_left.get_reflected_light() > 30 and color_right.get_reflected_light() > 30:
    wait_for_seconds(0.01)
motors.stop()

# Fine adjustment loop
for i in range(100):
    l_light = color_left.get_reflected_light()
    r_light = color_right.get_reflected_light()

    l_spd = 12 if l_light > 30 else 0
    r_spd = 12 if r_light > 30 else 0

    if l_spd == 0 and r_spd == 0:
        break

    motors.start_tank(l_spd, r_spd)
    wait_for_seconds(0.02)

motors.stop()

# STEP 4: Final Telemetry Verification
print("=== SEQUENCE COMPLETE ===")
print(f"Left Sensor (Port C): {color_left.get_reflected_light()}% [Black: {color_left.get_color()}]")
print(f"Right Sensor (Port D): {color_right.get_reflected_light()}% [Black: {color_right.get_color()}]")
print(f"Final Calibrated Yaw: {hub.motion_sensor.get_yaw_angle():.1f}°")
print("Robot is ready for attachment trigger!")
⏭️ Next Step
Now that your autonomous navigation algorithms are tournament-ready, proceed to Tutorial 4: Robot Architecture, Hardware Port Mapping & Calibration → to configure custom robot chassis, remap hardware ports, and test attachments in the stationary Dyno Jig!